Inspect pre-solved models in your browser in 2 seconds (up to 300k DOF) or solve 1.5M+ DOF assemblies 100% offline on Windows and macOS.
Planetary Gear Set with Orbiting Planets: 16-Step Contact
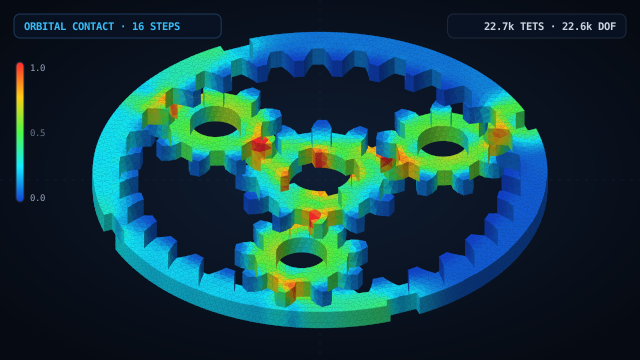
5-body epicyclic gear train (sun z_s = 12, three orbiting planets z_p = 9, fixed internal ring z_r = 30) solved across 16 steps of sun rotation (63°), carrier orbital motion (18°), and simultaneous unilateral Mortar contact in 6 mesh zones.
In epicyclic gearboxes, input torque on the sun gear splits across three planets that simultaneously mesh externally with the sun and internally with the stationary ring gear while their centers orbit along the carrier circle. This 5-body B-Rep assembly models a complete planetary stage (z_s = 12, three planets z_p = 9 at 0°/120°/240° on orbit radius R_orb = 42 mm, and internal ring gear z_r = 30, module m = 4 mm, α = 25°, face width b = 6 mm). Across 16 steps, the sun rotates through 63°, the planet axes orbit through 18° along the carrier circle, and each planet spins by −60° about its moving pin axis. Rigid orbital kinematics are separated from elastic tooth deflections (X₀ + u_rigid + s·u_el), and torque balance across all 6 mesh zones is verified within 5% on every step.
1. Geometry & FEA Mesh
- •5 disconnected B-Rep solid bodies (mesh components = 5): sun gear (z_s = 12, R_pitch = 24 mm, 66 faces), three identical planet gears (z_p = 9, R_pitch = 18 mm, R_orb = 42 mm, 39 faces each), and stationary internal ring gear (z_r = 30, R_pitch = 60 mm, 138 faces).
- •Materials: 18CrNiMo7-6 case-hardened carburized steel (E = 210 GPa, ν = 0.29) for sun gear; 42CrMo4 alloy steel (E = 206 GPa, ν = 0.29) for all three planets and internal ring gear.
- •Independent non-conforming tetrahedral meshes across all 5 bodies: 22,672 tetrahedra, 7,541 nodes, and 22,623 DOFs.
- •16-step orbital and rotational history (loadStepHistory) with separate rigidDisplacement and elastic displacement fields.
2. Loads & Boundary Conditions
- •Sun bore centered at (0, 0) and all three orbiting planet bores constrained along their local radial normal (component=normal, u_n = 0) at each orbital step, locking pin centers on the carrier while allowing free spin.
- •Outer cylindrical surface and keyway stops of the ring gear constrained normally (component=normal); rear planar faces of all 5 bodies constrained along Z (component=z, u_z = 0).
- •Pure driving torque T_sun = 66.46 N·m applied via 90 MPa normal pressure on the 4 CCW spline drive faces of the sun gear (total line-of-action tooth force ΣF_n = 3,055 N shared across 3 planets).
3. Simulation Results & Findings
- ✓Across all 16 orbital steps (θ_sun = 0°…63°, θ_orb = 0°…18°), torque splits evenly across all three planets with total Sun–Planet and Planet–Ring normal tooth forces matching theoretical ΣF_n = 3,055 N within ≤ 4.9% leak tolerance on 16/16 steps.
- ✓Reference step peak normal contact pressure p_contact = 358.1 MPa and von Mises stress σ_vm = 188.0 MPa across the 6 simultaneous tooth engagement zones.
- ✓Elastic tooth deflection |u_el| = 0.019–0.023 mm cleanly isolated from the 13.2 mm rigid orbital arc of the planets.
WebCAE solves multi-body epicyclic gear trains with simultaneous internal and external Mortar tooth contacts and orbiting carrier kinematics, enabling direct evaluation of load sharing, tooth root stress, and contact pressure across the full planetary mesh cycle.
14 days of full Pro access. The first charge occurs only after 14 days unless canceled beforehand.
- ✓14-Day Trial ($0 Today) (cancel anytime)
- ✓Up to 1.5M+ DOFs (direct sparse solver)
- ✓Native Windows & macOS Apps (100% offline)
- ✓Nonlinear Contact & Buckling (Kσ, MITC4, RBE2/RBE3)
Ask an Engineer About Your Model
Describe your part, load case, or CAD format — we reply within 2 business hours.
Want an instant answer on FEA theory or this model?
Click the AI chat button in the bottom-right corner to ask about boundary conditions, stress criteria, mesh convergence, or DSL scripting.
More Engineering Simulation Cases
Involute Spur Gear Pair: 16-Step Rotational Contact
Stepped Drive Shaft, Hub & Parallel Key
Split Clamping Hub on Hollow Drive Shaft Assembly (3 Bodies)