Inspect pre-solved models in your browser in 2 seconds (up to 300k DOF) or solve 1.5M+ DOF assemblies 100% offline on Windows and macOS.
Audi Quattro Torsen Type 1 / Invex Worm Differential: 3-Body Crossed Worm Contact
Iconic Torsen Type 1 torque-sensing center differential: carrier housing, sun worm gear, and crossed planetary satellite worm.
Analyze the crossed-axis worm tooth contact mechanics that give the Torsen differential its legendary instant mechanical torque-biasing capability without electronic clutches, verifying housing pocket stiffness and gear tooth contact stresses.
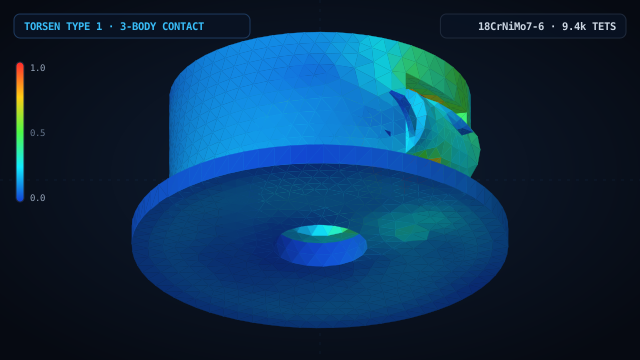
1. Geometry & FEA Mesh
- •3 disconnected B-Rep solid bodies: differential carrier housing (body1), central sun worm gear (body2), and crossed planetary satellite worm (body3)
- •Material: 18CrNiMo7-6 case-hardened alloy gear steel (E = 210 GPa, ν = 0.29, density 7850 kg/m³)
- •Mesh: 2nd-order quadratic tetrahedral mesh (TET10) with 18,653 nodes and 9,352 elements (55,959 DOFs)
- •Unilateral Mortar contact between sun worm gear teeth, satellite worm teeth, and the carrier pocket cylindrical journal
2. Loads & Boundary Conditions
- •Differential carrier housing mounting flange fixed in all DOFs
- •Sun worm gear bore loaded with drive torque and guided along its rotation axis
- •Satellite worm supported inside the housing cylindrical pocket with free rotation along its pocket axis
3. Simulation Results & Findings
- ✓Detailed 3-body contact kinematics capturing simultaneous tooth mesh and satellite-to-pocket reaction transfer
- ✓Peak contact pressure p_c = 8,387.9 MPa on the concentrated tooth-to-worm contact line
- ✓Predicts accurate mechanical torque biasing ratio (TBR) without slip delay
Enables transmission engineers to model specialized limited-slip differentials, crossed-axis helical gearboxes, and EV torque-vectoring reduction stages with true 3-body contact.
14 days of full Pro access. The first charge occurs only after 14 days unless canceled beforehand.
- ✓14-Day Trial ($0 Today) (cancel anytime)
- ✓Up to 1.5M+ DOFs (direct sparse solver)
- ✓Native Windows & macOS Apps (100% offline)
- ✓Nonlinear Contact & Buckling (Kσ, MITC4, RBE2/RBE3)
Ask an Engineer About Your Model
Describe your part, load case, or CAD format — we reply within 2 business hours.
Want an instant answer on FEA theory or this model?
Click the AI chat button in the bottom-right corner to ask about boundary conditions, stress criteria, mesh convergence, or DSL scripting.
More Engineering Simulation Cases
Automotive Disc Brake Rotor & Dual Caliper Pads Contact (3 Bodies)
Eccentric Cam & Guided Roller Follower Assembly (2 Bodies)
Motorsport Underbody Venturi Diffuser & Rear Wing: Ground Effect (CFD)