Inspect pre-solved models in your browser in 2 seconds (up to 300k DOF) or solve 1.5M+ DOF assemblies 100% offline on Windows, macOS, and Linux.
Deployable 8-Sector Umbrella Assembly: Runner-Driven Closure onto Central Shaft & Canopy Unfolding Cycle
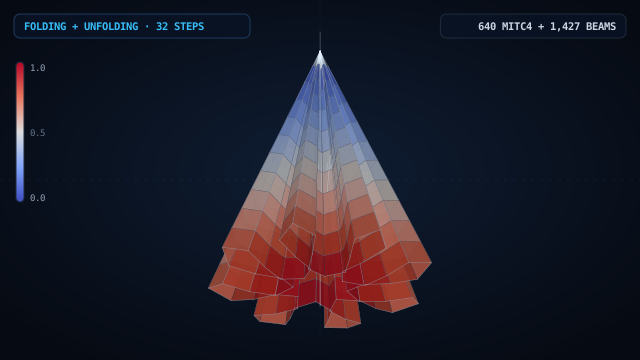
Geometrically nonlinear multi-step simulation (loadpath="1,0.03", 62 equilibrium snapshots) of an 8-sector umbrella mechanism driven solely by the sliding runner sleeve (Node 3) with zero forces on the canopy: 8 straight ribs (deviation 0.001 mm) and 8 straight stretchers fold down along the shaft while the 640-quad MITC4 canopy forms 8 vertical star-shaped pleats.
Deployable umbrella mechanisms operate as spherical-hinge linkages coupled with a thin membrane canopy: as the runner sleeve (Node 3) is driven all the way down the central shaft (uz = -321.3 mm) with zero artificial loads applied to the canopy, 8 straight stretchers hinged without bending moment at top and bottom pull the 8 straight ribs inward along the central shaft (ring radii R = 7 → 15 → 22 → 30 → 38 → 45 → 53 → 61 → 69 → 76 → 84 mm, straightness deviation 0.001 mm), while the 8 polyester fabric panels between the ribs fold outward into 8 vertical star-shaped pleats (R_pleat = 256.7 mm). Reversing the runner travel back up the shaft unfolds the pleats and restores the octagonal canopy (Steps #1–#28 closure and Steps #29–#62 unfolding along loadpath="1,0.03").
1. Geometry & FEA Mesh
- •Refined 4x canopy mesh: 733 mesh nodes (717 document nodes + 16 duplicate hinge nodes), 640 4-node corotational MITC4 shell elements (64 circumferential segments × 10 radial rings, thickness t = 0.35 mm), and 1,428 Timoshenko beam elements.
- •Central tubular shaft (Ø16 × 2.5 mm, L = 645 mm) with a spherical handle point mass (350 g at z = 0), sliding runner sleeve at z = 425 mm, 8 straight tubular stretchers (Ø12 × 3.5 mm with moment-free spherical release hingeJ="all" at the rib joint), and 8 straight main ribs (Ø16 × 5.0 mm with moment-free spherical release hingeI="all" at the top crown).
- •Outward star-pleat seeding across the 8 inter-rib fabric gores so that as the 8 straight ribs are pulled inward by the runner, the fabric folds outward between the ribs purely by structural coupling.
- •All 62 converged equilibrium snapshots (savedSnapshots = 62) embedded directly in the .wce bundle.
2. Loads & Boundary Conditions
- •Central shaft supported at the handle (Node 1), lower guide (Node 2), and top crown hub (Node 4), while the runner sleeve (Node 3) is guided strictly along the vertical shaft axis (ux = uy = rx = ry = rz = 0).
- •Actuation applied exclusively to the lower strut attachment hub (runner Node 3) along the shaft axis via a stiff axial actuator over non-monotonic path loadpath="1,0.03", with zero nodal loads on the 704 canopy nodes.
- •Stage I (Steps #1–#28, λ = 0 → 1.0): downward travel of Node 3 (uz = -321.3 mm) pulling the stretchers, straight ribs, and canopy inward; Stage II (Steps #29–#62, λ = 1.0 → 0.03): upward return of Node 3 (uz = -10.3 mm) unfolding the canopy.
3. Simulation Results & Findings
- ✓At peak closure (Step #28, λ = 1.000): runner Node 3 moves down by uz = -321.3 mm (to z = 103.7 mm), pulling all 8 straight ribs and stretchers along the central shaft (ring radii R = 7 → 15 → 22 → 30 → 38 → 45 → 53 → 61 → 69 → 76 → 84 mm, rib straightness deviation only 0.001 mm over 520 mm), while the 8 fabric panels form vertical outward star pleats (R_pleat = 256.7 mm) with von Mises shell stress σ_vm = 27.6…656.1 kPa.
- ✓Upon reverse unfolding (Step #62, λ = 0.030): runner Node 3 returns to uz = -10.3 mm, rib tips expand back to R_rib = 515.7 mm, pleats open to R_pleat = 545.1 mm, and the unfolded octagonal canopy exhibits a symmetric von Mises stress distribution (σ_vm = 2.9…71.4 kPa).
- ✓Fundamental natural frequency f₁ = 3.39 Hz (4 modes) and linear buckling critical factor λ₁ = 0.001 confirming thin-membrane folding compliance.
Demonstrates WebCAE's ability to simulate deployable beam-and-membrane mechanisms, pantograph linkages, and foldable aerospace/architectural canopies driven purely from the actuator hub through full closure and reverse unfolding cycles.
14 days of full Pro access. The first charge occurs only after 14 days unless canceled beforehand.
- ✓14-Day Trial ($0 Today) (cancel anytime)
- ✓Up to 1.5M+ DOFs (direct sparse solver)
- ✓Native Windows, macOS & Linux Apps (100% offline)
- ✓Nonlinear Contact & Buckling (Kσ, MITC4, RBE2/RBE3)
Ask an Engineer About Your Model
Describe your part, load case, or CAD format — we reply within 2 business hours.
Want an instant answer on FEA theory or this model?
Click the AI chat button in the bottom-right corner to ask about boundary conditions, stress criteria, mesh convergence, or DSL scripting.
More Engineering Simulation Cases
Involute Spur Gear Pair: 20-Step Finite Rotation (+90°) & Tooth Contact
Planetary Gear Stage: 20-Step Sun Rotation (+180°) & Orbiting Planets
Stepped Drive Shaft, Hub & Parallel Key