Inspect pre-solved models in your browser in 2 seconds (up to 300k DOF) or solve 1.5M+ DOF assemblies 100% offline on Windows and macOS.
Mobile Crane Outrigger with Hydraulic Jack, RBE2 Spider & Contact Pad
Geometrically nonlinear 3D hybrid beam-shell crane outrigger combining a horizontal box boom (z = 0.42 m), vertical hydraulic jack leg (240 kN), 9-slave RBE2 spider foot, and unilateral contact between the jack shoe (z = 0.065 m) and ground distribution mat (z = 0.0 m).
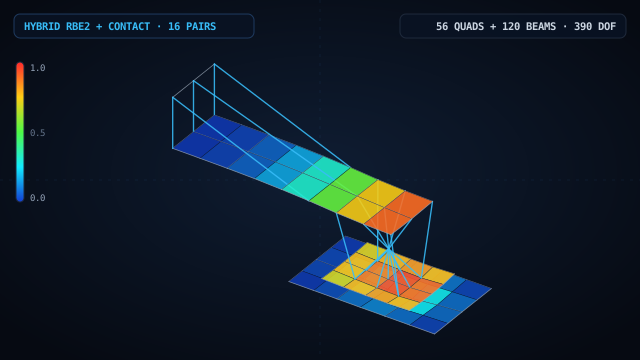
Heavy mobile crane outriggers transfer hundreds of kilonewtons of overturning reaction from the crane chassis into ground support mats through a distinct three-tier spatial structure: a high-mounted horizontal box boom, a vertical hydraulic jack cylinder at the boom tip, and a steel jack foot shoe bearing onto a wider ground distribution mat. In this WebCAE model, the horizontal outrigger boom (1.50 × 0.44 m, 16 MITC4 quads of t₁ = 10 mm at z = 0.42 m with longitudinal spars, transverse diaphragms, and inclined Ø64 mm tubular tie-rods from the z = 0.68 m chassis portal) carries a vertical hydraulic jack leg at x = 1.125…1.50 m. The jack piston rod (master node 91 at z = 0.22 m) drives a 9-slave RBE2 spider into the steel jack foot shoe (0.42 × 0.42 m, 16 MITC4 quads of t₂ = 12 mm at z = 0.065 m), which presses across a 2.0 mm initial physical clearance onto the lower ground mat (0.72 × 0.64 m, 24 MITC4 quads of t₃ = 14 mm at z = 0.0 m). Under 240 kN vertical jack load, 16 contact pairs engage cleanly, deflecting the shoe by -3.39 mm and the ground mat by -1.81 mm with zero RBE2 constraint violation.
1. Geometry & FEA Mesh
- •91 nodes, 56 MITC4 shell quads, 120 beam elements, 390 active DOFs.
- •Horizontal outrigger boom: length 1.50 m, width 0.44 m, skin t₁ = 10 mm at z = 0.42 m, reinforced with 30 × 45 mm spars, 24 × 38 mm ribs, and Ø64 × 7 mm portal tie-pipes.
- •Vertical hydraulic jack leg: Ø88 × 10 mm central cylinder + 4 tubular guide posts (Ø42 × 5 mm) descending from boom tip (z = 0.42 m) to jack foot shoe (z = 0.065 m).
- •Jack RBE2 spider: master node 91 at (1.3125, 0.30, 0.22 m) coupled to 9 slave nodes on the jack shoe via rigid kinematic constraints.
- •Jack foot shoe (0.42 × 0.42 m, t₂ = 12 mm at z = 0.065 m) and ground distribution mat (0.72 × 0.64 m, t₃ = 14 mm at z = 0.0 m) separated by 65 mm mid-surface distance.
2. Loads & Boundary Conditions
- •Full 6-DOF clamping of root nodes along x = 0 m (crane chassis frame) and upper portal nodes (z = 0.68 m).
- •Perimeter clamping of the lower ground distribution mat (z = 0.0 m).
- •240 kN vertical downward jack force (F_z = -240,000 N) applied at hydraulic piston rod master node 91.
- •Two-sided shell contact across the 65 mm vertical offset (slaveoffset = 31 mm, masteroffset = 32 mm -> 2.0 mm clearance, penalty = 3e8 N/m).
3. Simulation Results & Findings
- ✓Nonlinear static solution converges in 6 load steps (27 Newton iterations, 0 cutbacks) with constraintMaxViolation = 0.
- ✓16 active contact pairs close the 2.0 mm clearance: boom deflects to u_z = -3.62 mm, jack shoe reaches u_z = -3.39 mm, and ground mat deflects to u_z = -1.81 mm.
- ✓Linear buckling analysis confirms stability of the tubular jack struts and boom: critical load factor λ₁ = 4.61.
- ✓Modal analysis yields first natural bending frequency f₁ = 30.24 Hz.
Allows crane and heavy equipment manufacturers to simulate the complete 3D structural load path—from chassis portal and horizontal box boom down through the hydraulic jack leg and RBE2 spider foot into the ground contact mat—in a single browser-ready hybrid model.
14 days of full Pro access. The first charge occurs only after 14 days unless canceled beforehand.
- ✓14-Day Trial ($0 Today) (cancel anytime)
- ✓Up to 1.5M+ DOFs (direct sparse solver)
- ✓Native Windows & macOS Apps (100% offline)
- ✓Nonlinear Contact & Buckling (Kσ, MITC4, RBE2/RBE3)
Ask an Engineer About Your Model
Describe your part, load case, or CAD format — we reply within 2 business hours.
Want an instant answer on FEA theory or this model?
Click the AI chat button in the bottom-right corner to ask about boundary conditions, stress criteria, mesh convergence, or DSL scripting.
More Engineering Simulation Cases
Two-Layer Stiffened Shell Buffer Panel with Thickness-Offset Contact
Jaw Crusher Movable Swing Jaw (900×600)
48 m Mine Hoist Headframe & Ore Bin