Inspect pre-solved models in your browser in 2 seconds (up to 300k DOF) or solve 1.5M+ DOF assemblies 100% offline on Windows and macOS.
Industrial Robot Cycloidal Speed Reducer: Multi-Lobe Pin Ring Contact
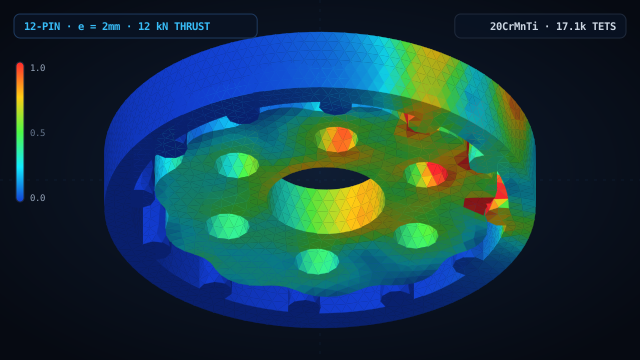
High-precision zero-backlash cycloidal speed reducer with 11 epitrochoid lobes, 12 housing roller pins, and 12 kN eccentric thrust.
Verify load division among simultaneously engaged cycloidal lobes, determine peak contact pressures and subsurface shear stresses on the 20CrMnTi roller pins, and prevent excessive disc flexure under high operating radial thrust.
1. Geometry & FEA Mesh
- •2 disconnected B-Rep solid bodies: 12-pin stator housing (body1) and 11-lobe cycloidal disc (body2)
- •Material: 20CrMnTi alloy case-hardened steel (E = 206 GPa, ν = 0.29, density 7820 kg/m³)
- •Mesh: 2nd-order quadratic tetrahedral mesh (TET10) with 31,324 nodes and 17,118 elements (93,972 DOFs)
- •Unilateral Mortar contact formulation between the outer epitrochoid lobe contour and all 12 cylindrical pins
2. Loads & Boundary Conditions
- •Outer mounting rim of the pin housing fixed in all 6 DOFs
- •Cycloid disc held against axial tilt (Uz = 0) with eccentric radial contact thrust Fx = 12.0 kN on inner bore
- •Frictionless contact constraint between disc lobes and pin roller surfaces
3. Simulation Results & Findings
- ✓Maximum deflection |u| = 0.1077 mm in the cycloidal disc under eccentric load
- ✓Peak contact pressure p_c = 2,649.8 MPa at the primary engaged pin contact zone
- ✓Von Mises stress σ_vm = 1,774.0 MPa localized in the engaged tooth root and drive pin pockets
Crucial for high-precision industrial robotics, collaborative robots (cobots), and aerospace rotary actuators requiring zero backlash, high torsional rigidity, and proven shock load tolerance.
14 days of full Pro access. The first charge occurs only after 14 days unless canceled beforehand.
- ✓14-Day Trial ($0 Today) (cancel anytime)
- ✓Up to 1.5M+ DOFs (direct sparse solver)
- ✓Native Windows & macOS Apps (100% offline)
- ✓Nonlinear Contact & Buckling (Kσ, MITC4, RBE2/RBE3)
Ask an Engineer About Your Model
Describe your part, load case, or CAD format — we reply within 2 business hours.
Want an instant answer on FEA theory or this model?
Click the AI chat button in the bottom-right corner to ask about boundary conditions, stress criteria, mesh convergence, or DSL scripting.
More Engineering Simulation Cases
Planetary Gear Set with Orbiting Planets: 16-Step Contact
Involute Spur Gear Pair: 16-Step Rotational Contact
Stepped Drive Shaft, Hub & Parallel Key