Inspect pre-solved models in your browser in 2 seconds (up to 300k DOF) or solve 1.5M+ DOF assemblies 100% offline on Windows and macOS.
Stick-to-Slip Breakaway of Flanged Spool in Robotic Parallel Gripper under Emergency Jerk
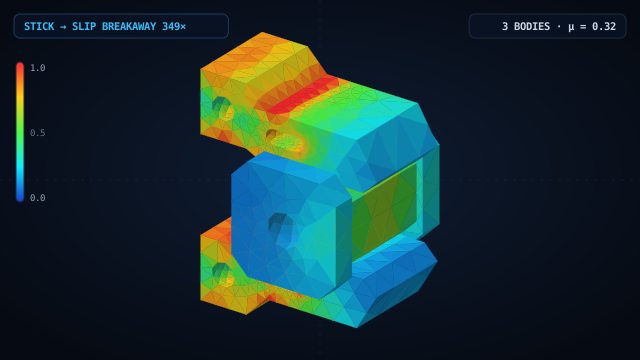
3-body B-Rep assembly of a parallel two-finger robotic gripper clamping an octagonal flanged spool, capturing the transition from static frictional retention (stick) to gross sliding breakaway (slip) during an emergency stopping jerk.
In high-speed industrial robotics, emergency stops (E-stops) generate severe inertial deceleration jerks that can overcome the normal clamping force of parallel gripper jaws and cause the payload to eject. This 3-body B-Rep assembly models left and right slotted gripper jaws (16 CAD faces each, with mounting flanges and pin bores) clamping an octagonal flanged workpiece spool (29 CAD faces) under 0.18 MPa actuator pressure. During the holding phase (t = 0…15 ms), bilateral friction (μ = 0.32) holds the spool in stick (0.0753 mm elastic shear). When the emergency deceleration ramp hits 470 m/s² (t = 15…60 ms), inertial force exceeds 2μF_N and the spool breaks away into 26.29 mm of gross slip.
1. Geometry & FEA Mesh
- •3 B-Rep CAD bodies (61 faces total): left gripper jaw (16 faces), right gripper jaw (16 faces), and octagonal flanged spool workpiece (29 faces, R = 5 mm bore, clamping flats at z = ±12 mm).
- •3-region tetrahedral mesh: 12,282 TET4 elements, 3,053 nodes, 9,159 DOFs.
- •Bilateral frictional contact pairs (body1 ↔ body3 and body2 ↔ body3, μ = 0.32, slip tolerance 0.15 mm) with 21 saved transient frames.
2. Loads & Boundary Conditions
- •Rear mounting bases of left and right gripper jaws fixed (fix surface number 42, 114).
- •Pneumatic/electric actuator clamping pressure p = 0.18 MPa applied to outer jaw drive pads (surface number 36, 117).
- •Two-stage emergency braking deceleration base_accel = {470, 0, 0} m/s² with amplitude="0:0,0.015:0.005,0.060:1.00".
3. Simulation Results & Findings
- ✓41 implicit HHT-α steps completed in 197 Newton-Raphson iterations (198 node-steps in stick, 368 node-steps in slip, 118 active-set facet transitions, 1.706 J frictional dissipation).
- ✓During the holding phase (t = 15 ms), workpiece displacement is held to 0.0753 mm (< slipTol = 0.15 mm).
- ✓During the emergency jerk (t = 60 ms), the workpiece breaks away and slides to |u|_max = 26.293 mm (349× the stick deformation).
WebCAE's multi-body frictional transient solver enables robotics and automation engineers to size gripper clamping forces against emergency-stop deceleration profiles and prevent part ejection.
14 days of full Pro access. The first charge occurs only after 14 days unless canceled beforehand.
- ✓14-Day Trial ($0 Today) (cancel anytime)
- ✓Up to 1.5M+ DOFs (direct sparse solver)
- ✓Native Windows & macOS Apps (100% offline)
- ✓Nonlinear Contact & Buckling (Kσ, MITC4, RBE2/RBE3)
Ask an Engineer About Your Model
Describe your part, load case, or CAD format — we reply within 2 business hours.
Want an instant answer on FEA theory or this model?
Click the AI chat button in the bottom-right corner to ask about boundary conditions, stress criteria, mesh convergence, or DSL scripting.
More Engineering Simulation Cases
2-Stage Industrial Parallel-Shaft Gearbox Cutaway (10 Bodies)
Tower CPU Cooler with 4 Copper Heatpipes on Motherboard Cutaway (9 Bodies)
Robotic Joint Strain Wave Gear (Harmonic Drive) Cutaway (8 Bodies)