WebCAE 1.0: Surface-to-Surface Mortar Contact in Finite-Deformation Statics, Geometry-Driven Beams & Shells, Full UI ⇄ DSL Parity, and All 30 WebCAE 101 Tutorials
WebCAE 1.0 ships across browser WebAssembly and native desktop builds (Windows, macOS, and Linux) with surface-to-surface Mortar contact and exact Rodrigues finite rotations in nlgeom, B-Rep geometry-driven 1D Timoshenko beams and 2D MITC4 shells, full bidirectional UI ⇄ DSL synchronization across 142 commands, new multi-body gear and biomedical showcase assemblies, one-click MCP AI setup, and the complete 30-lesson WebCAE 101 curriculum with a 386-page verified PDF handbook.
- Release version
- v1.0.0 (Web & Desktop)
- UI ⇄ DSL parity
- 142 verified commands
- WebCAE 101 curriculum
- 30 lessons (F01–F30)
- Complete PDF Handbook
- 386 pages · Verified
We are proud to announce WebCAE 1.0 for browser WebAssembly and native desktop platforms (Windows, macOS, and Linux). This milestone release brings together surface-to-surface Mortar contact mechanics in finite-deformation statics, direct B-Rep structural modeling for 1D beams and 2D shells, complete bidirectional synchronization between the visual interface and the scripting language (DSL), new multi-body industrial assemblies, one-click MCP integration for local AI assistants, and the complete 30-lesson WebCAE 101 engineering curriculum.
1. Surface-to-Surface Mortar Contact & Finite Rotations in nlgeom on
The geometrically nonlinear static solver (nlgeom on) now features optional surface-to-surface Mortar contact (formulation=mortar, marked experimental) alongside node-to-surface contact. Contact pressure is integrated over the clipped overlap of slave and master facets (Dunavant and Gauss triangle quadrature; Tri6 faces are split into conforming sub-triangles) with a smoothed slave normal field and a consistent tangent stiffness, so the contact patch test passes exactly on non-matching meshes. Mortar covers frictionless unilateral contact and bilateral tied/bonded interfaces under large displacements (Coulomb friction remains on the node-to-surface formulation), while Remote Point kinematic couplings use exact finite-rotation Rodrigues kinematics for large-angle rotational loading.
2. Geometry-Driven 1D Timoshenko Beams & 2D MITC4 Shells from B-Rep
Engineers can now build spatial beam frames, stiffened panels, and thin-walled shell structures directly on imported STEP/IGES or procedural B-Rep geometry without writing low-level node coordinates. Select CAD edges or faces in the 3D viewport, assign standard beam profiles (I-beam, channel, box, pipe, rectangular, circular) with custom orientation vectors and eccentric offsets via Assign Beam, or assign shell thicknesses and extract mid-surfaces automatically via Mid-Surface. The conformal 1D/2D mesher shares nodes along imprinted ribs and intersections, supports vertex, edge, and surface boundary conditions, and outputs full 3D deformed shapes together with axial, shear, torsional, and bending internal force diagrams (N, Qy, Qz, Mx, My, Mz).
3. Full Bidirectional UI ⇄ DSL Synchronization (142 Verified Commands)
Every setup operation in the ribbon and model tree now translates live into clean, deterministic DSL script statements — and any script edits immediately update the visual preprocessor tree and 3D scene. Full round-trip parity spans 142 verified commands, including remote points, lumped point masses, bolt preloads, elastic foundations, compression-only supports, symmetry planes, gravity, centrifugal and bearing loads, surface heat flux, convection, Stefan–Boltzmann radiation, and nonlinear load-stepping controls.
4. Industrial Contact Assemblies & One-Click MCP AI Bridge
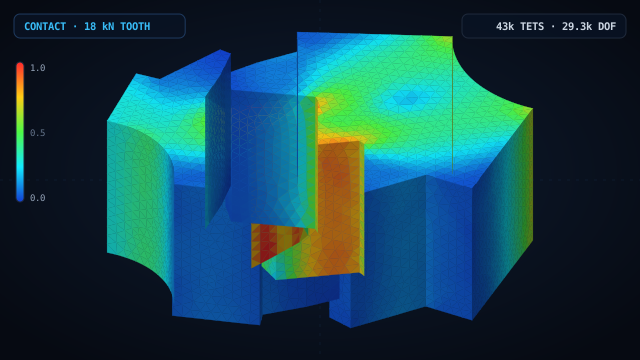
The interactive 3D showcase library adds new verified multi-body contact assemblies: an involute spur gear pair under spline driving torque, a 5-body epicyclic planetary gear stage with six simultaneous tooth contact zones, and a bi-metallic orthopedic hip implant assembly (Ti-6Al-4V ELI stem and CoCrMo femoral head on a 12/14 Morse taper) tested under ISO 7206-4 endurance loading. In addition, the new MCP Setup menu in the application topbar lets you connect local AI engineering agents (Claude Desktop, Cursor, Claude Code) to WebCAE's typed simulation tools in a single click.
Involute Spur Gear Pair Under Driving Torque (gear_mesh_contact)
Two-body alloy steel involute spur gear pair (z₁ = 12, z₂ = 16, m = 4 mm, a = 56 mm) under 66.46 N·m spline torque with unilateral Mortar tooth contact and base-circle force verification.
F_n = 3,061.2 N (3.88% vs T/r_b1) · p_n = 1,226.4 MPa · |u|_max = 0.0501 mm
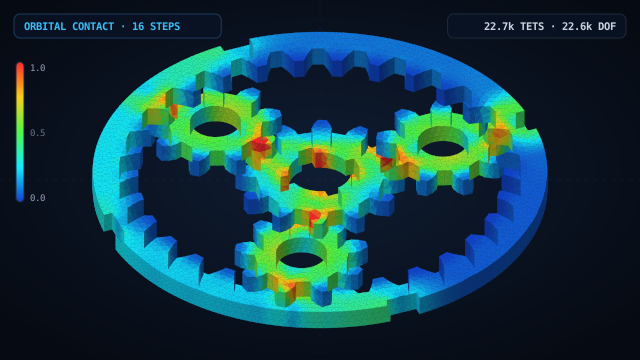
Planetary Gear Stage with 6 Simultaneous Contact Zones (planetary_gear_contact)
Five-body planetary gearset (sun z_s = 12, three planets z_p = 9, stationary ring z_r = 30) solving three-way torque splitting across six unilateral Mortar tooth interfaces.
5 bodies · 6 contact pairs · p_n = 739.4 MPa · |u|_max = 0.1006 mm
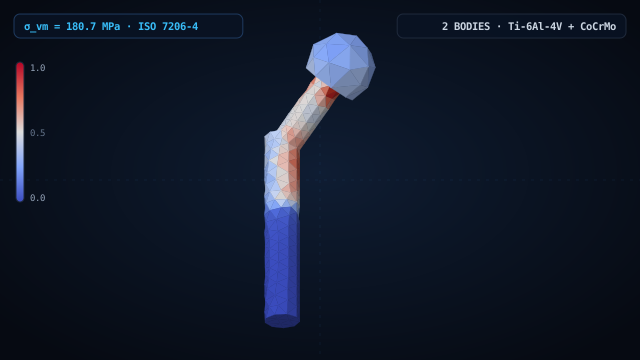
Total Hip Arthroplasty Implant under ISO 7206-4 Load (hip_implant_iso7206)
Two-body orthopedic hip prosthesis (Ti-6Al-4V ELI stem + CoCrMo Ø32 mm modular head on a 12/14 Morse taper) under a 2,300 N vertical joint force applied through an RBE2 head-center spider.
σ_vm = 180.7 MPa (0.14% vs analytical) · |u|_max = 0.1942 mm · SF = 4.40
5. Complete WebCAE 101 Curriculum: All 30 Verified Lessons & 386-Page Handbook
All 30 interactive step-by-step tutorials (F01–F30) in the WebCAE 101 curriculum are now live at /docs/tutorials and inside the application. The curriculum spans linear and nonlinear statics, mesh convergence, natural frequencies, Euler buckling, steady and transient heat transfer, thermoelastic bimetallic strips, Hertzian line contact, frictional snap-fits, 3D parametric and direct CAD modeling, sheet metal unfolding, CAD defeaturing, mid-surface shell extraction, coupled stiffened panels, and MCP AI automation. Every lesson is illustrated with real browser screenshots, executable DSL snippets, and side-by-side comparisons against analytical textbook formulas, and the entire 30-lesson series is compiled into a downloadable 386-page PDF handbook.